The Problem
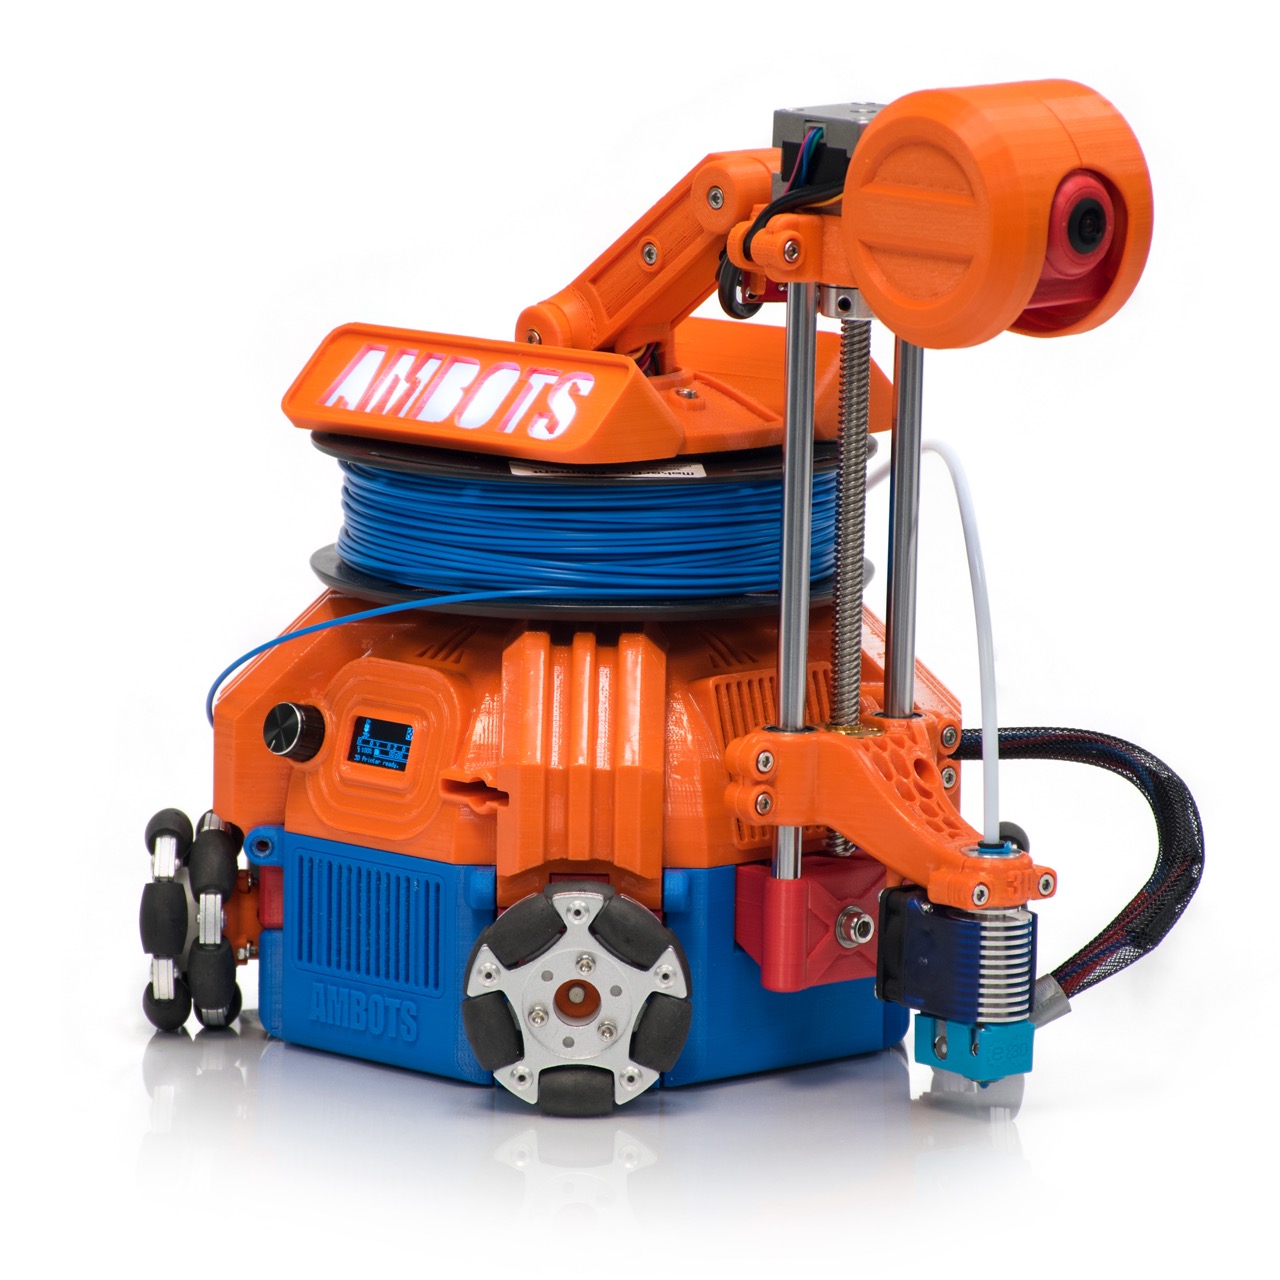
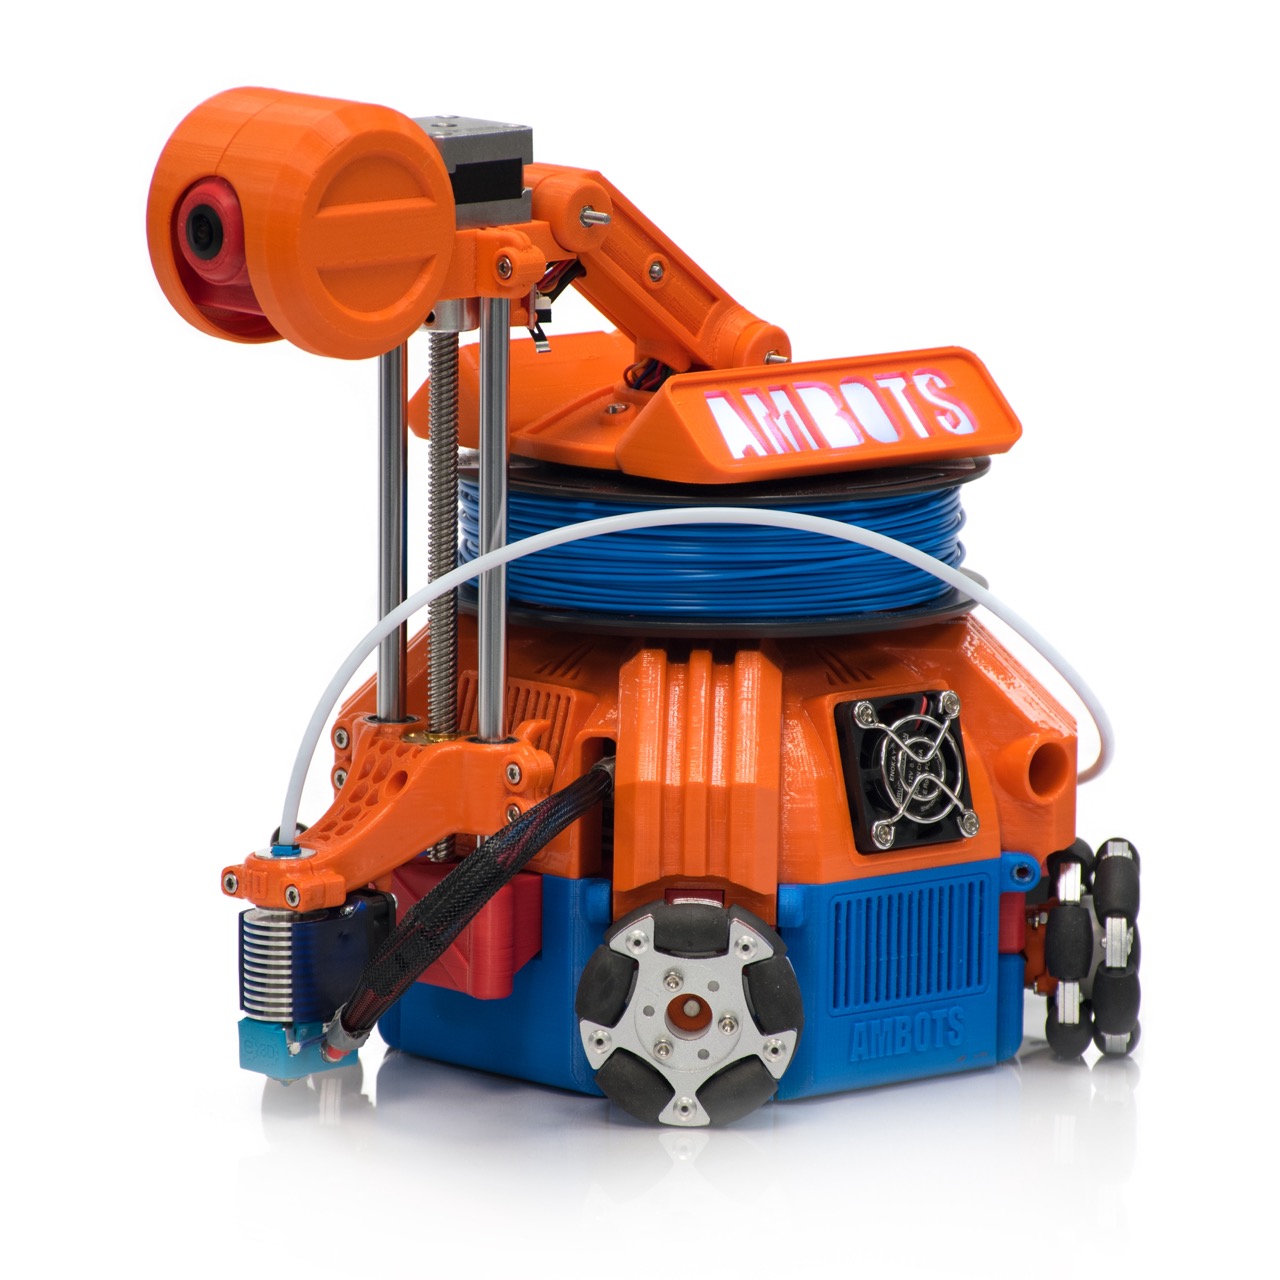
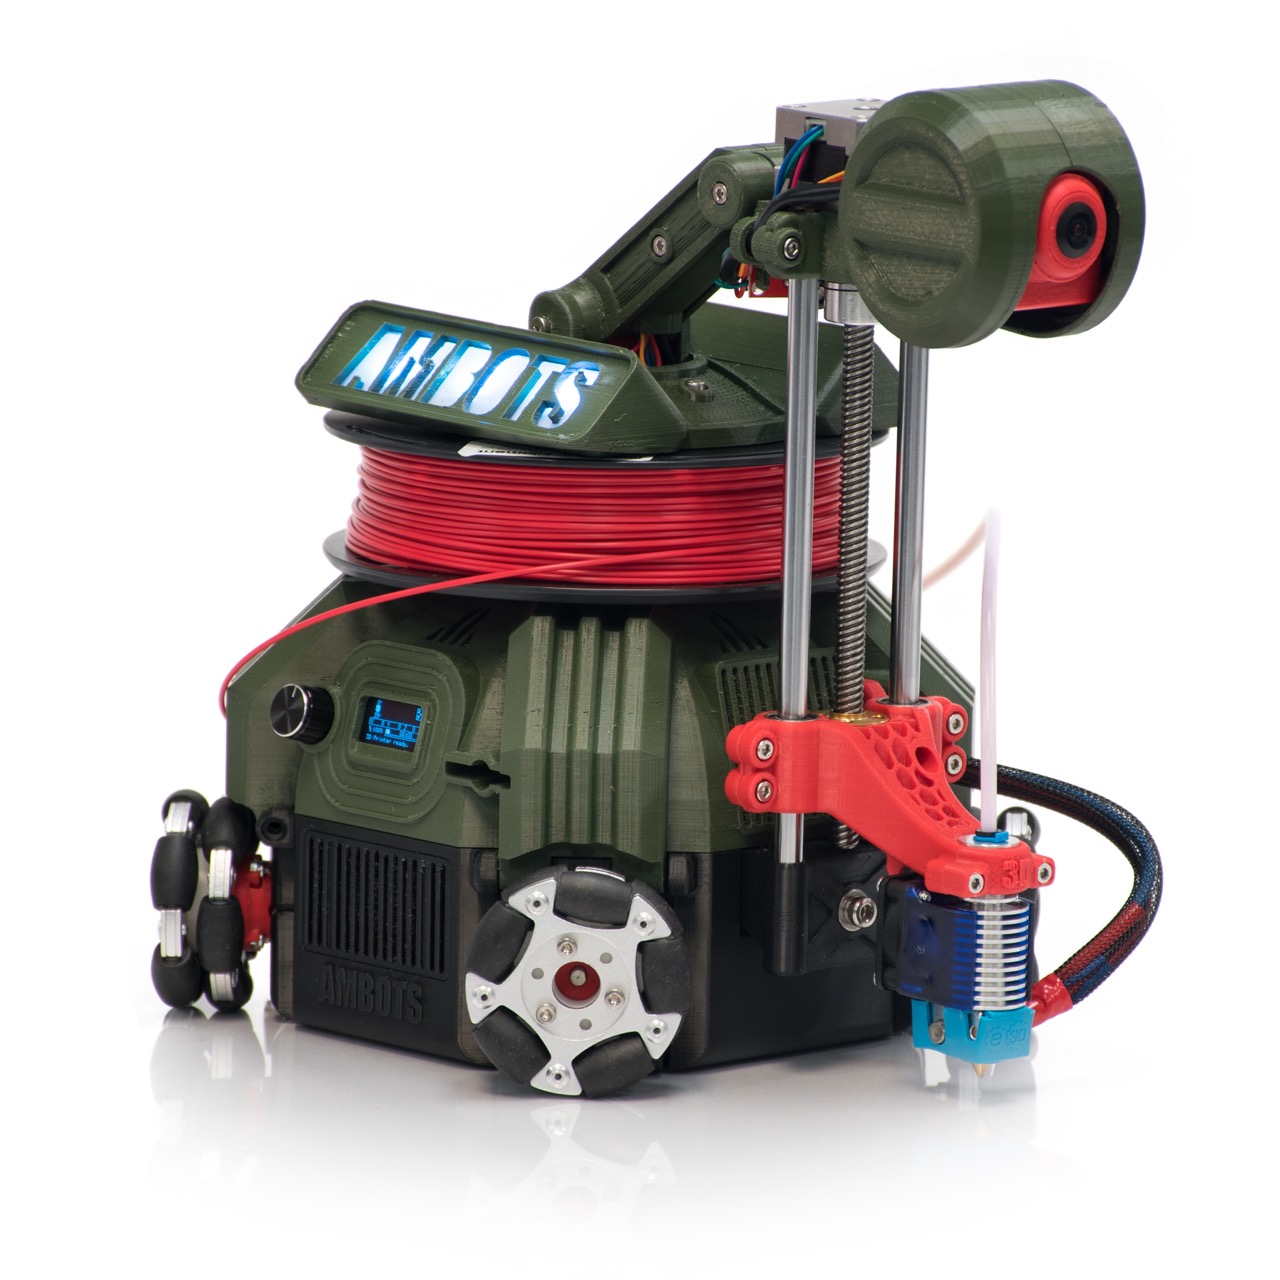
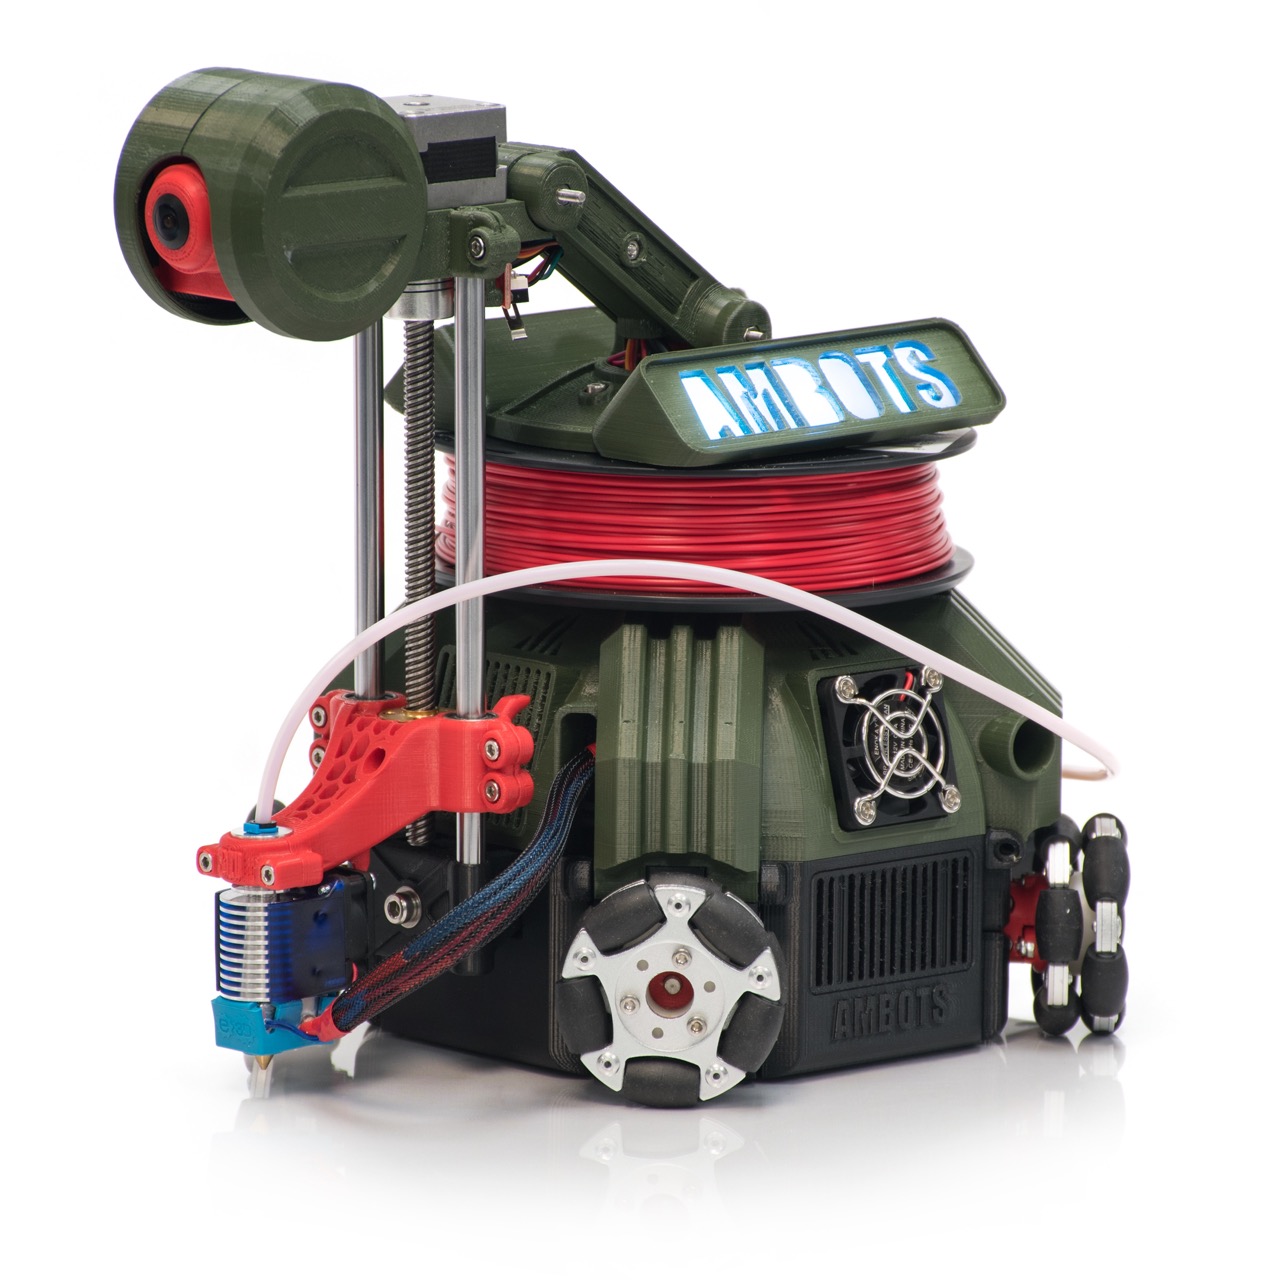
To realize the vision of cooperative 3D printing, we needed a printer that wasn't confined to a box. The challenge was to build a mobile robot capable of carrying a printhead and moving precisely across a shared floor space, allowing robots to work together beyond a fixed printer frame.
The Engineering
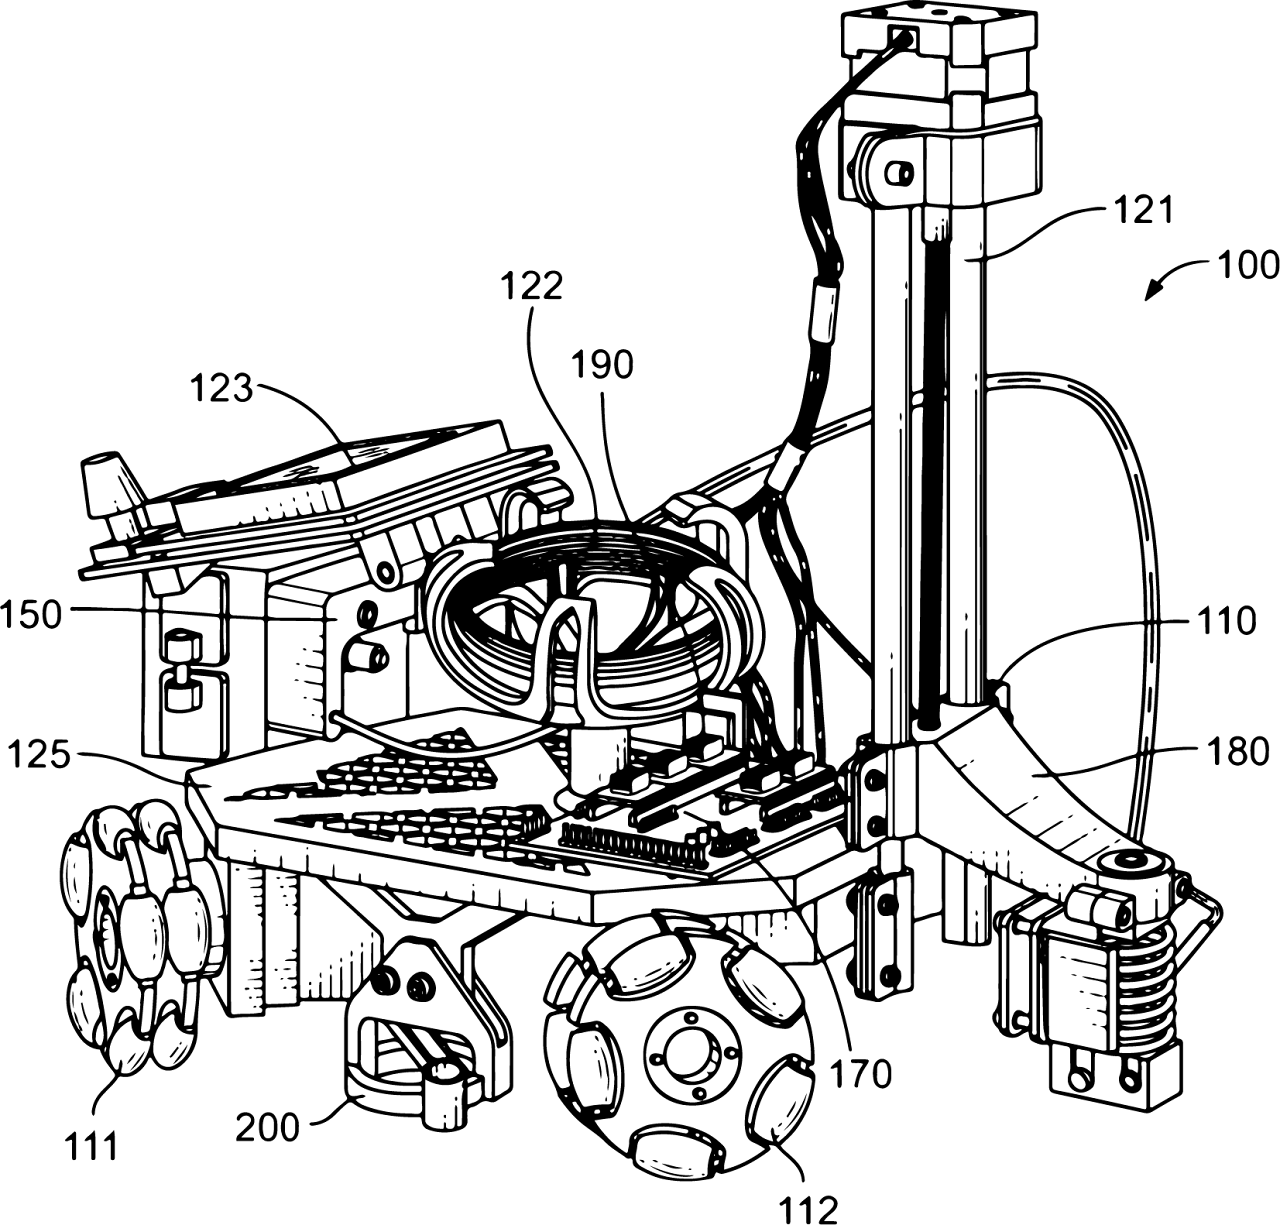
I developed two revisions of the robot hardware, including custom control circuit boards, the mechanical enclosure, and the firmware. I adapted the open-source Marlin firmware to support omnidirectional wheels for holonomic X-Y movement and implemented a closed-loop control system using optical sensors to track the robot's precise displacement on the floor.
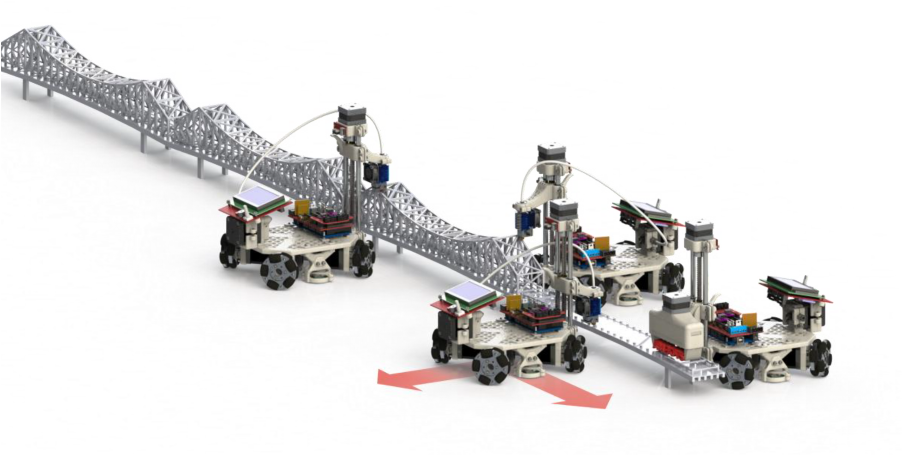
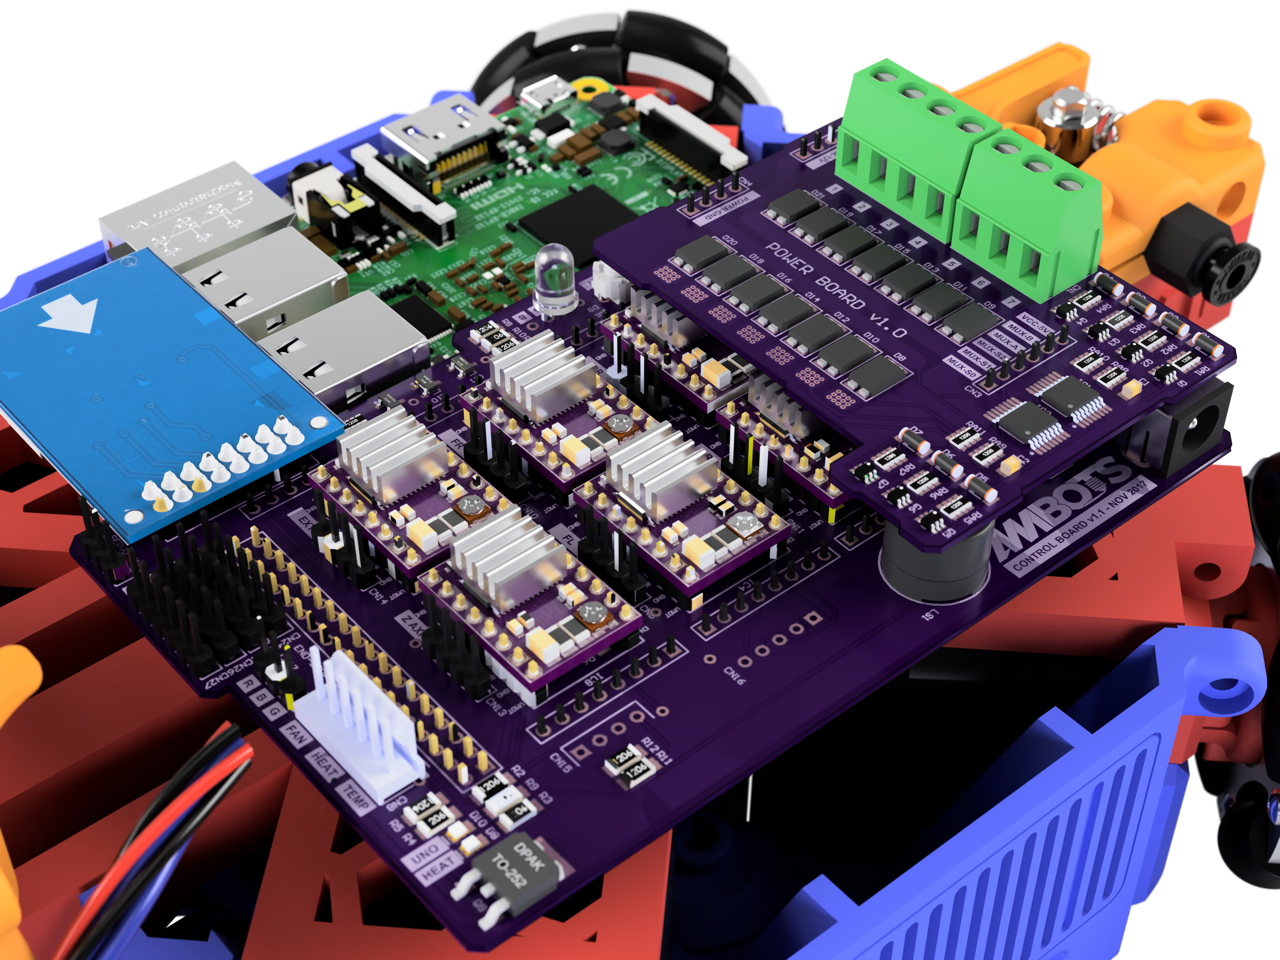
Watch the simulated printer translate across the build area. The omnidirectional wheel arrangement allows X–Y motion beyond a fixed printer frame; this is a simulation rather than prototype footage.
The Results
I built two working prototypes that successfully demonstrated the concept of mobile manufacturing. The design was recognized at the international 3D Pioneers Challenge in Germany, receiving a special mention from Autodesk, and resulted in a patent and a published paper.
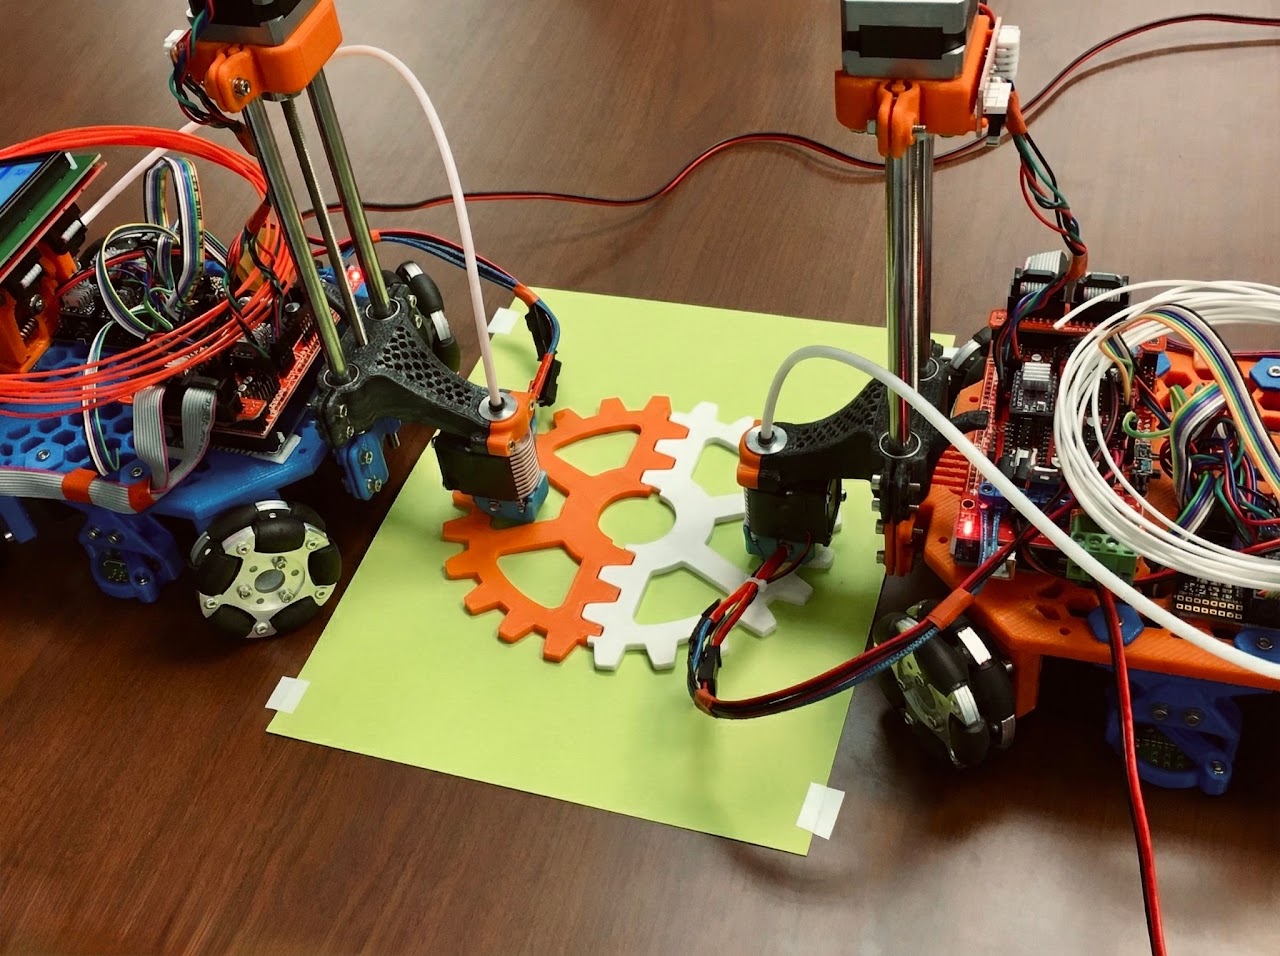
Prototype Gallery