The Problem
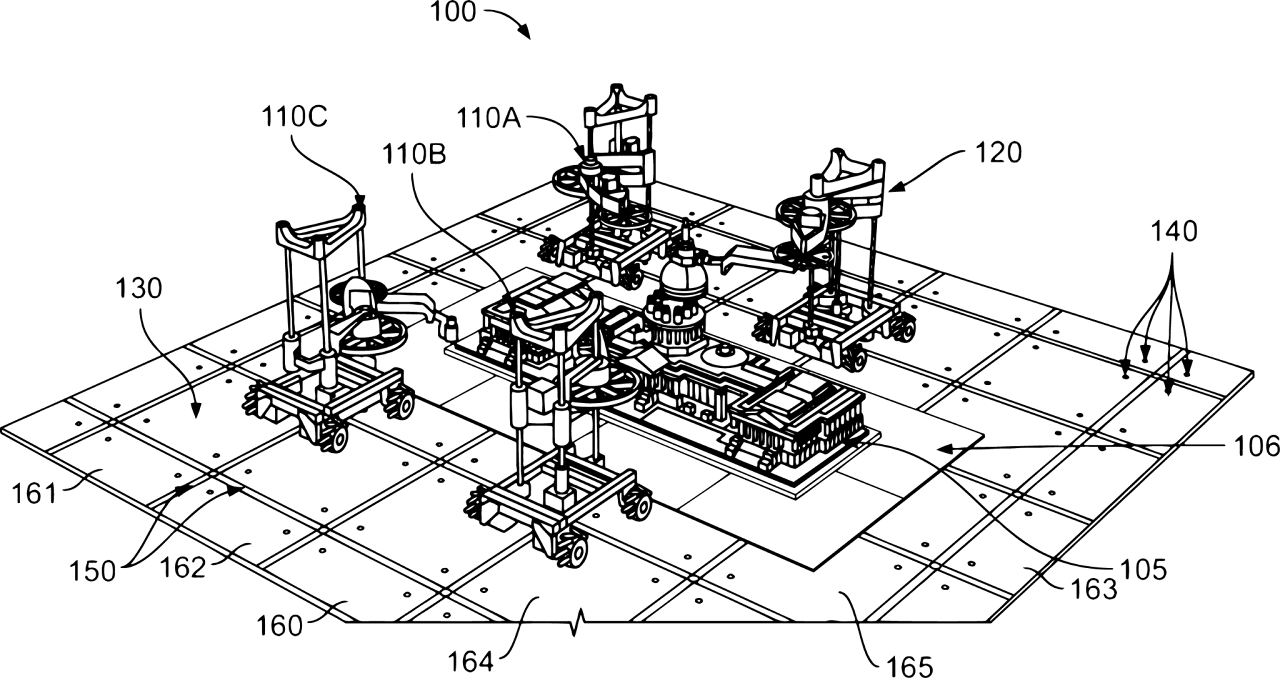
Traditional 3D printing is limited by speed and build volume; a single nozzle can only move so fast. We aimed to create a "swarm manufacturing" platform where multiple mobile robots collaborate on a single print job. The challenge was to coordinate these independent agents to print large-scale objects simultaneously without collision or conflict.
The Engineering
I led the platform’s hardware and software engineering, including custom circuit boards, mechanical components, and C++ and Python firmware. The workflow connects CAD partitioning, task scheduling, SCARA printing, and robot transport so multiple printers can contribute to one build.
- Partition the model
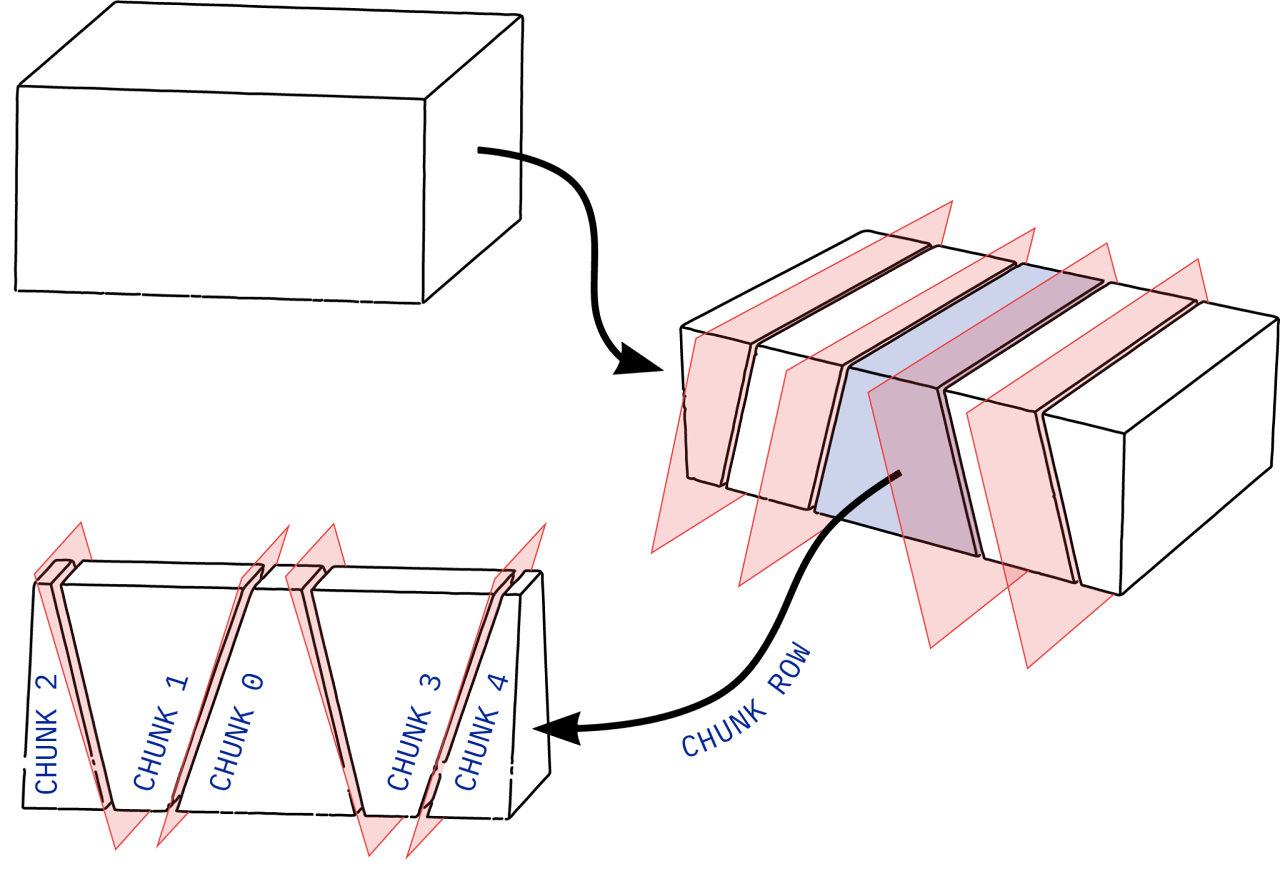
The chunking algorithm divides the CAD model into printable tasks for individual SCARA arms.
- Coordinate the print
A central scheduler manages task assignments and dependencies as the robots share the build.
- Relocate the printers
The Transporter follows floor codes using IR sensors, moving printers to new positions while supplying power and data during transit.
The Results
The demonstrations below show both parts of the workflow: two robots printing simultaneously on a shared 900 × 300 mm surface, and the Transporter relocating a printer during an active job. Together, they show the platform coordinating parallel printing and printer movement within one build.
On large prints, the platform reduced print time by 50%, saving roughly 17 hours. The work also resulted in two patents and two published papers.
View the research funding records for award amounts, recipients, and my contributions.
Watch both print heads deposit material at the same time on one 900 × 300 mm surface, showing how two printers contribute to a shared build.
Watch the Transporter pick up and relocate a printer while the job continues, demonstrating movement between work areas during a build.